2026-11-03 (3): Multithreading, Project Talk#
Multithreading, And Race Conditions#
Doing Multiple Things In Parallel#
Here’s a sketch running the PLC loop and the commandline loop in parallel, using multithreading.
#include <print>
#include <thread>
#include <unistd.h>


class Motor
{
public:
    enum Direction { FORWARD, BACKWARD, NONE };
    void forward() { _direction = FORWARD; }
    void backward() { _direction = BACKWARD; }
    void stop() { _direction = NONE; }

private:
    Direction _direction;
};

class FSM
{
public:
    enum State { OPEN, CLOSED, OPENING, CLOSING };

public:
    FSM(Motor& motor) : _motor(motor), _state(OPEN) {}

    State state() const { return _state; }
    const char* state_str() const
    {
        switch (_state) {
            case OPEN: return "OPEN";
            case CLOSED: return "CLOSED";
            case OPENING: return "OPENING";
            case CLOSING: return "CLOSING";
        }
        return "OJE";
    }

    void dwim_pressed()
    {
        switch (_state) {
            case OPEN:
                _motor.backward();
                _state = CLOSING;
                break;
            case CLOSED:
                _motor.forward();
                _state = OPENING;
                break;
            case OPENING:
                _motor.backward();
                _state = CLOSING;
                break;
            case CLOSING:
                _motor.forward();
                _state = OPENING;
                break;
        }
    }
    void open_position_reached()
    {
        switch (_state) {
            case OPEN:
                std::println("wtf?");
                break;
            case CLOSED:
                std::println("wtf?");
                break;
            case OPENING:
                _motor.stop();
                _state = OPEN;
                break;
            case CLOSING:
                std::println("wtf?");
                break;
        }
    }
    void closed_position_reached()
    {
        switch (_state) {
            case OPEN:
                std::println("wtf?");
                break;
            case CLOSED:
                std::println("wtf?");
                break;
            case OPENING:
                std::println("wtf?");
                break;
            case CLOSING:
                _motor.stop();
                _state = CLOSED;
                break;
        }
    }

private:
    Motor _motor;
    State _state;
};

class Button
{
public:
    bool is_pressed() { return true; }
};


Motor motor;
FSM fsm(motor);

Button dwim;
Button closed_position;
Button open_position;

void plc_loop()
{
    // PLC loop
    while (true) {
        if (dwim.is_pressed())
            fsm.dwim_pressed();
        if (closed_position.is_pressed())
            fsm.closed_position_reached();
        if (open_position.is_pressed())
            fsm.open_position_reached();

        std::println("state: {}", fsm.state_str());

        sleep(1);
    }
}

void cmdline_loop()
{
    while (true) {
        char buffer[1024] = {0};
        ssize_t nread = read(0, buffer, sizeof(buffer)-1);
        if (nread == -1) {
            perror("read");
            break;
        }

        std::println("debug line: {}", buffer);

        std::string line = buffer;
        if (line == "dwim\n")
            fsm.dwim_pressed();

        std::println("state: {}", fsm.state_str());
    }
}

int main()
{
    std::thread plc_thread(plc_loop);
    std::thread cmdline_thread(cmdline_loop);

    plc_thread.join();
    cmdline_thread.join();

    return 1;
}
The Consequences Of Doing Multiple Things In Parallel#
Livehacked …
#include <print>
#include <thread>

uint64_t the_number = 0;

void increment_10_000_000_times()
{
    uint64_t n_loops = 10'000'000;
    while (n_loops--) {
        the_number++;
    }
}


int main()
{
    std::thread t1(increment_10_000_000_times);
    std::thread t2(increment_10_000_000_times);

    t1.join();
    t2.join();

    std::println("the_number: {}", the_number);
    return 0;
}
Expected output: 20000000
Actual output (varies): 10475662
$ ./2026-11-03-mother-of-all-race-conditions
the_number: 10475662
Project: First Tasks#
Door Finite State Machine#
Test driven development of the FSM class in the middle. Cornerstones:
Knows the motor (see below) ⟶ defines the interface
Does not know any button. Rather, provides methods (like, “dwim pressed”, “open position reached”, “closed position reached”) to inject events that might have their origins in buttons - but not necessarily. (See Door Commandline)
Buttons: Edge Detection#
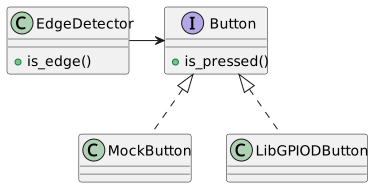
Button interface is level based - you ask it whether its state is
“pressed” or “released”.
The FSM wants events that we need compute from the levels, in a 1ms PLC polling loop.
Around a Button, wrap another object that can be asked if an edge
(configurable: rising, falling) has been detected. UML might look like
this:
Keep an eye on followup task “debouncing”.
Hardware: GPIO On The Pi#
Setup a Pi
Do some research on
libgpiod(a library to control GPIOs on Linux)Focus on immediate feature (see Buttons: Edge Detection): input, level based. Goal is to implement
LibGPIODButtonin the UML diagram from Buttons: Edge DetectionKeep an eye on hardware based edge detection and debouncing which will be one of the next steps
Door Commandline#
Create a program that can be used to manually test the FSM. That program …
Instantiates a dummy Motor implementation (derived from interface
Motoras defined by the FSM).As a first step, this implementation would simply output something like “left”, “right”, “stop” in calls to the methods with the same name.
Instantiates a FSM instance which knows the motor.
Reads from stdin in a loop, like
cmdline_loop()in the sample program in Doing Multiple Things In Parallel.The program does not use multithreading like the sample program does.
Check how the
readlinelibrary can be used in place of rawread(STDIN_FILENO, ...), to provide history browsing.Understands commands that drive the FSM, or report state, like …
DWIM button pressed
Open position reached
Closed position reached
Report motor state (left, right, stopped)
Report FSM state
…
Motor#
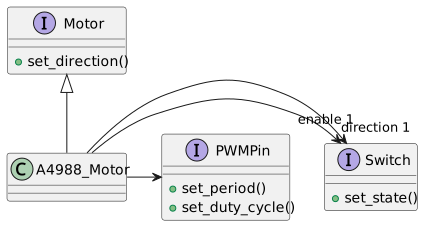
The door’s stepper motor is controlled by a A4988 chip. The A4988 requires two GPIO pins configured as output for direction/enable, and a PWM pin for the motor speed.
Goal 1: define interfaces for
SwitchandPWMPinGoal 2: based on mock implementations of those, write a number of tests.
Goal 3: make tests run.