Firmware: Initial Version (Driven By Interrupts)#
Observations#
Interrupts are nested
7 beats 42 and timer
All logic is in ISRs
Reading GPIO state is fine
SPI flash write is not (adds more interrupts)
Network/CAN IO is not (adds even more interrupts)
Demo: tmux Layout, Initialization, Startup#
For your orientation: an explanation of the terminal screen layout that is used throughout the course.
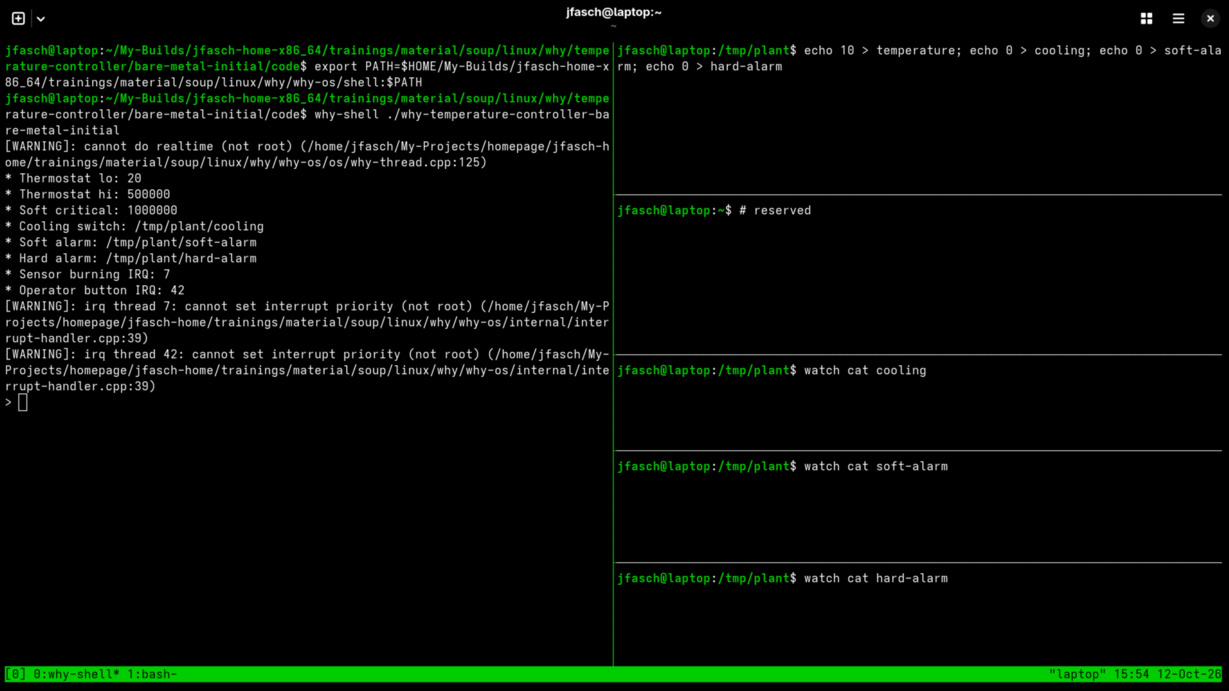
Left: application
$ export PATH=$HOME/My-Builds/jfasch-home-x86_64/trainings/material/soup/linux/why/why-os/shell:$PATH
$ why-shell ./why-temperature-controller-bare-metal-initial      # or whatever program
Right 1: “Plant Management”
Set all to “off”#$ cd /tmp/plant $ echo 10 > temperature $ echo 0 > cooling $ echo 0 > soft-alarm $ echo 0 > hard-alarm
Right 2: Later (CAN-Bus)
Right 3: Cooling switch
$ cd /tmp/plant
$ watch cat cooling
Right 4: Soft alarm
$ cd /tmp/plant
$ watch cat soft-alarm
Right 5: Hard alarm
$ cd /tmp/plant
$ watch cat hard-alarm
Demo: Switch On Cooling#
Right 1: Set temperature above “thermostat high”
$ echo 500001 > temperature
⟶ cooling on
Demo: Enter Soft Alarm#
Right 1: Set temperature above “soft critical”
$ echo 1000001 > temperature
⟶ soft alarm on (cooling remains on)
Demo: Operator Intervention#
Left: inject “operator button” IRQ
> irq 42⟶ soft alarm off (cooling remains on)
Demo: Sensor Burning#
Left: inject “sensor burning” IRQ
> irq 7⟶ hard alarm on, cooling off